01
Purpose
The aim is a system that can process ongoing experience, maintain an evolving internal model, and learn from the relationship between what it expected and what actually happened.
A moving speaker is more than a sequence of images and sounds. Those signals may describe one person, across delays, interruptions, and changes in viewpoint. The architecture asks how a machine could form that connection, remember it, anticipate what comes next, and revise it when it is wrong.
Metacognition enters through that ability to evaluate and adjust its own processing. Machine consciousness remains the long-horizon ambition; neither a connected representation nor a useful self-model would, by itself, establish subjective experience.
02
Research questions
Joint representation
What can different senses share in an encoding, and what must retain its original units, timing, and interpretation?
Temporal binding
How can delayed or interrupted streams be related without mistaking coincidence for a common source?
Persistent reference
How do entities and relationships survive when input changes, and how can mistaken associations be undone?
Prediction and reflection
Can expected and observed outcomes guide processing without letting a system confirm its own guesses?
Online learning
How can experience change representations and behavior while preserving useful knowledge and bounded resource use?
Continuous output
How can media and action outputs keep their own timing while the internal model continues to process new input?
03
System design
The intended scope is five input families—video, audio, text, body state, and touch—with text, audio, video, and bounded control outputs. Live sensors, recorded replay, and simulated worlds are proposed ways to exercise the same core.
Video · Audio · Text · Body state · Touch
Modality adapters retain source, event time, and uncertainty.Predict and compareTiming
Relate sensory eventsReference
Maintain relationships
Memory, routing, and feedback connect these mechanisms over time.
Text · Audio · Video · Bounded actions
Each output retains its own pacing and constraints.Action changes the world; new observations return to the system.
This view shows responsibilities, not a settled sequence of neural layers. A shared transport format, a shared memory representation, and shared meaning are different problems. The research must establish which operations actually connect them.
04
Three connected mechanisms
Twelve architecture explorations led to three expanded designs. The working hypothesis is that they may describe complementary parts of the original system, rather than mutually exclusive replacements. Their contribution—and their compatibility—still needs testing.
Change / Predictive Delta Fabric
Record what differs from expectation.
Predictive delta encoding would concentrate on information-bearing changes while keeping enough state to reconstruct what is happening. Quiet or predictable input could require less work, leaving more capacity for unexpected events.
The hard question: can it reduce computation or storage without losing stable facts, accumulating reconstruction error, or confusing noise with novelty?
Timing / Phase-Locked Resonant Workspace
Explore how separate signals belong to one event.
Changing signals are represented through temporal or phase relationships. Their interaction could create a temporary shared representation across senses, developing the timing ideas behind HipNet and RoTE.
The hard question: does this improve on ordinary timestamp alignment? Signals can coincide without sharing a cause, and related signals can arrive at different times.
Reference / Referential Hypergraph Codec
Keep identities and relationships through change.
Referential channels and relational binding would connect observations to entities, events, and one another. The aim is memory that can retain and retrieve these relationships as experience accumulates.
The hard question: can new references improve recall and prediction without false identity merges, irreversible mistakes, or unbounded growth?
The mechanisms should be independently switchable in experiments. A combined system earns its complexity only if it improves on simpler alternatives under comparable conditions.
05
Component roles
These names remain part of the design vocabulary. The table describes intended responsibilities and unresolved contracts; it is not a list of completed modules.
| Component | Intended role | Open design question |
|---|---|---|
| Pre-trained Semantic Encoder (Pre-SeEn) | Adapt sensory input into representations the core can process. | What is shared, what remains modality-specific, and what can be reconstructed? |
| Process Router (ProRo) | Allocate processing between familiar patterns and material requiring learning or further evaluation. | How are novelty, uncertainty, urgency, and noise distinguished? |
| HipNet and RoTE | Support temporal context, memory, and relationships across processing cycles. | How are different rates, delays, clock drift, and long-term continuity handled? |
| RefChans and RefRo | Develop and route through referential structures for concepts, entities, and relationships. | When are references created, revised, merged, or removed? |
| Expectation Generator (ExGen) | Predict upcoming states or outcomes from current input and memory. | What is predicted, over which horizon, and against what baseline? |
| Affective State Module (ASM) | Explore evaluative signals arising from expected–observed differences; originally framed as affective simulation. | What does the signal mean, and how should it influence processing? |
| Recursive Feedback Module (RFM) | Return evaluated information to the internal process for refinement. | What limits recursion and prevents self-reinforcing mistakes? |
| Cumulative decoder and output processors | Translate internal state into media, text, or bounded control output. | How are fidelity, timing, confidence, and action constraints preserved? |
06
Research approach
Use conventional architectures where they help; keep the central representation problem open to experimental computation and compression. The project explores beyond familiar model designs without requiring novelty for its own sake.
Type-punned representations, bit-level packing, temporal codes, and relational structures are possible tools, not explanations by themselves. A common data type does not automatically create common meaning. Biological analogies likewise motivate questions rather than validate a mechanism.
Global workspace
How specialized processes might share information through a constrained common workspace.
Memory and temporal coding
How sequence, context, retrieval, and prediction might contribute to continuity.
Predictive processing
How differences between expectation and observation can guide attention and learning.
Attention and routing
How limited processing capacity can be directed toward relevant or unfamiliar information.
07
Development status
System architecture and experiments
The v0.5 architecture, twelve explorations, three expanded designs, and component test matrices are documented. These establish the design work, not an integrated implementation.
Neural-system and online-learning work
An early neural-system scaffold and separate OnlineZephyr learning experiments provide implementation lineage. Neither is presented as validation of the combined architecture.
Robotics self-model control loop
A separate reference implementation has a recorded five-test unit-test checkpoint. This is bounded software evidence, not a demonstration of the full cognitive system or physical control.
Integrated performance
A complete, reproducible demonstration of the combined multimodal architecture is not provided here. The site makes no claim of demonstrated machine consciousness, general intelligence, or production readiness.
Inspect the Robotics baseline: source, five tests, reproduction steps, and limitations. This separate component does not implement or validate the proposed multimodal system.
Design targets, simulation results, component tests, and hardware observations will be reported separately. Stronger capability claims need a named configuration, a method, results, and inspectable limitations.
08
Development record
Metacognition as the starting question
The first recovered public statement centers machines reflecting on their own processing.
A modular Conscious Model
ProRo, RefChans, HipNet, RoTE, ExGen, ASM, and recursive feedback appear in the version 0.2 concept.
Long-form architecture and learning experiments
A fuller project overview accompanies a separate line of experiments on online learning and retention beyond the active context.
Version 0.5 and the system rebuild
The diagram develops multimodal encoding, temporal processing, referential channels, and output. A partial rebuild revisits the input-to-HipNet path.
Experimental architectures and integration questions
Twelve configurations lead to three expanded designs and shared tests. Discussion then asks how change, timing, and reference could work together—and where that combination could fail.
View the earlier v0.2 architecture
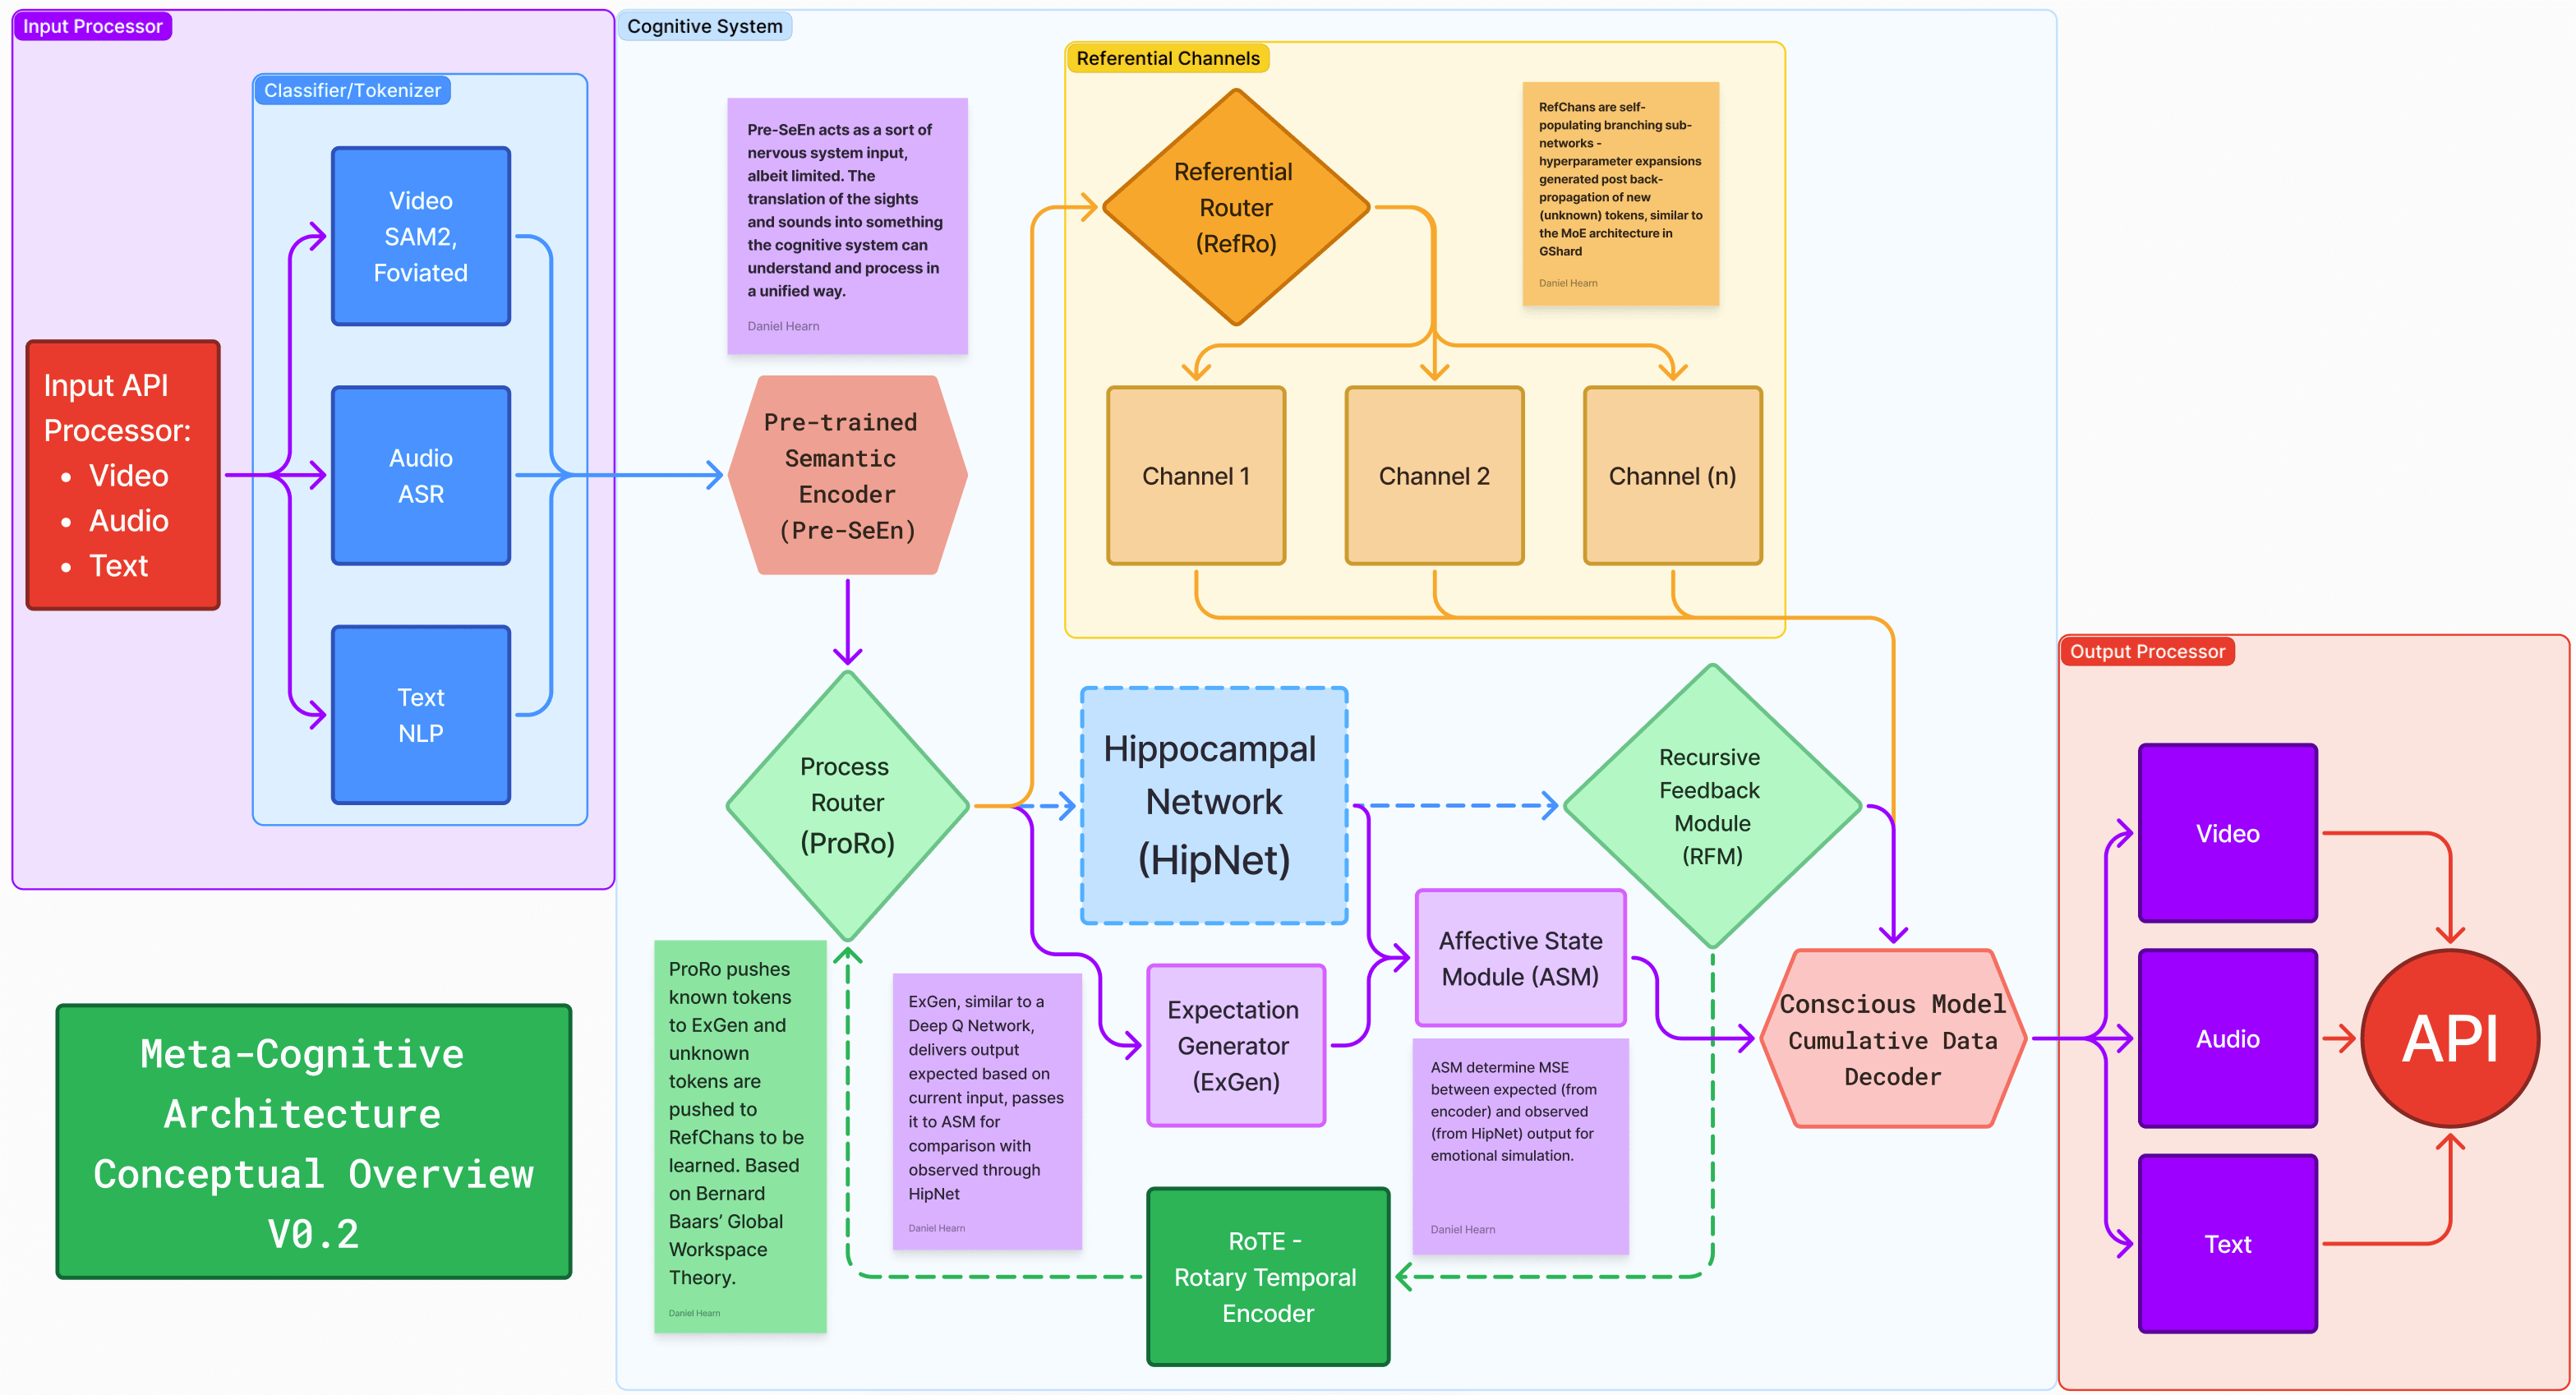
09
Test the mechanisms—and the connections.
The design includes a shared live/replay/simulation harness and component-level tests. The following comparisons describe the proposed evaluation program, not completed experiments or a claim that the harness is implemented.
Do the mechanisms together add value beyond the best simpler system at comparable compute and latency? A useful negative result should tell us which assumption to change.
Embodied work may eventually connect the project to Conscious Effort Robotics and Hearn Aero, but physical-system claims remain configuration-specific and independently gated.
10
Selected references
These works inform the questions. They do not validate the project's architecture.
- Baars, B. J. (1988). A Cognitive Theory of Consciousness. Cambridge University Press.
- Bach, J. (2009). Principles of Synthetic Intelligence PSI: An Architecture of Motivated Cognition. Oxford University Press.
- Tononi, G. (2004). “An information integration theory of consciousness.” BMC Neuroscience, 5, 42.
- Vaswani, A., et al. (2017). “Attention Is All You Need.” Advances in Neural Information Processing Systems.
- Dehaene, S. (2014). Consciousness and the Brain. Viking.
Contact
Questions, criticism, and collaboration are welcome.
Especially useful: evaluation design, temporal representation, persistent-state systems, online learning, multimodal integration, and safety-aware control.
Contact the project